Oct 2026
Diffusion Policy: how robots learn from human demos
Diffusion Policy is a 2023 research method that helps robots learn a task from human demonstrations. Here's how that works and where it goes wrong.
 Sir Toastimir
The idea
Diffusion Policy starts from a simple idea: this robot never read a manual. It learned from a human showing it what to do.
Someone steers the robot through the task with a controller, over and over, showing it what to do. The robot learns from those examples, then copies the move on its own. It's basically monkey see, monkey do.
Where it goes wrong
One wrong copy can send the robot somewhere it never saw while it was learning, and then it gets lost. It's a bit like following a friend's directions and taking one wrong turn. Suddenly nothing looks familiar.
The 2023 trick
Diffusion Policy, a method that researchers from Columbia, Toyota Research Institute and MIT first published in 2023, helps with that. Instead of deciding one move at a time, it thinks several moves ahead at once. If there's more than one right way to grab something, it just picks one and commits. That makes it steadier.
The takeaway
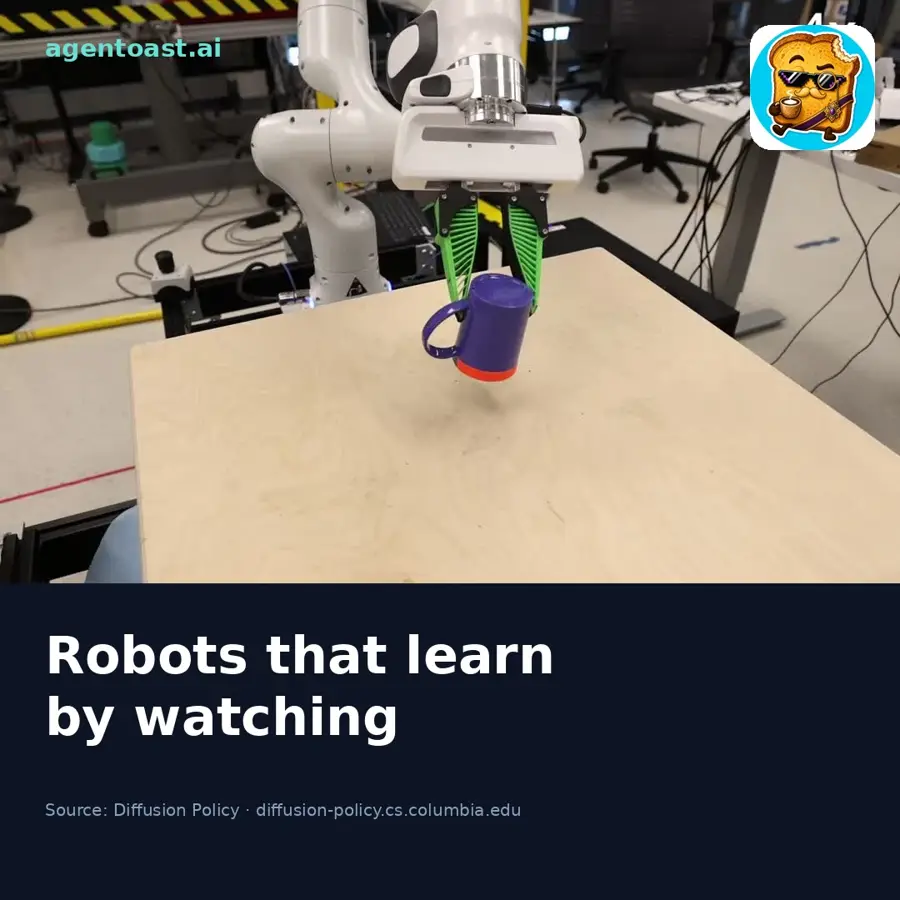
Either way, a robot is only as good as the examples it learned from. Better examples, better robot. The project page below has fun videos of real robots pushing blocks and grabbing mugs.
Links
Get your daily slice of AI
One short email with the best new AI tools, robots and AI & tech stock news. Free. Unsubscribe anytime.
We only use your email to send the newsletter.